Muqing Cao’s Home Page
I am a Faculty Early Career Award Fellow at Engineering Systems and Design (ESD) pillar at the Singapore University of Technology and Design (SUTD). My research interests are aerial robots, multi-robot systems, robot learning, and decision-making. My research goal is to realize intelligent and reliable robot teams in the real world.
I am looking for outstanding students interested in robotics to work with me as PhD/master students, research assistants and visiting students. If you are interested, please get in touch by email with your CV and a brief note on your research interests.
Previously, I was a postdoctoral fellow at Robotics Institute, Carnegie Mellon University. I obtained my PhD and bachelor degree from Nanyang Technology University, Singapore. If you are interested in my research, please contact me via email: muqing_cao AT sutd.edu.sg.
News
- 2026/09I am happy to serve as an Associate Editor for ICRA 2027 in the Perception and Learning area!
- 2026/08I received the Faculty Early Career Award and will be joining the Engineering Systems and Design (ESD) pillar at the Singapore University of Technology and Design (SUTD)!
- 2026/07We are organizing the IROS 2026 Workshop and Competition on Intelligent Information Gathering for Single and Multi-Robot Systems!
- 2026/07We are organizing the IROS 2026 workshop on Beyond Exteroception: Interoceptive Perception for Resilient Robotics!
- 2026/07We are organizing the iros 2026 IMU Odometry Challenge!
- 2026/04Our IJRR paper Braid-based entanglement-free trajectory planning for multiple tethered robots received an honorable mention for IJRR Paper of the Season!
- 2026/02I serve as a program committee member of RSS Pioneers 2026!
- 2026/02I gave a guest lecture at CMU graduate course Multi-Robot Planning and Coordination!
- 2026/02I gave a talk at Pennsylvania State University Systems, Controls, and Robotics seminar series!
- 2026/02Our paper on online informative path planning (IA-TIGRIS) has been accepted at IEEE T-RO!
- 2025/12Our paper on multi-robot entanglement-free trajectory planning has been accepted by IJRR (paper link)!
- 2025/10I gave a guest lecture at Texas A&M University CSCE 689-600: Special Topics in Multi-Robot Systems (course link)!
- 2025/07We are organizing the IROS 2025 2nd Workshop and Competition on Multi-Robot Perception and Navigation Challenges in Logistics and Inspection Tasks!
- 2025/06One paper and one workshop proposal accepted to IROS 2025!
- 2025/04I am selected as a RSS Pioneer 2025 (14.6% acceptance)!
- 2025/04I will serve as a co-chair of the session "Human Motion Sensing" at ICRA 2025!
- 2025/01Four papers accepted to ICRA 2025!
- 2024/10I have started a position as a postdoctor at CMU AirLab!
- 2024/10We successfully organized IROS 2024 Workshop and Competition on Multi-Robot Perception and Navigation Challenges in Logistics and Inspection Tasks (website). Thanks to all speakers and participants!
- 2024/06We are organizing the Cooperative Aerial Robots Inspection Challenge (CARIC) (website) in conjunction with IROS 2024 Workshop!
- 2024/06Our paper on a novel hybrid aerial-ground manipulator has been accepted by IROS 2024!
- 2023/10Our paper on a novel hybrid aerial-ground robot has been awarded the IROS 2023 Best Entertainment Paper!
- 2023/03Our paper on trajectory planning multi-tethered robots has been accepted by T-RO!
Research Highlights
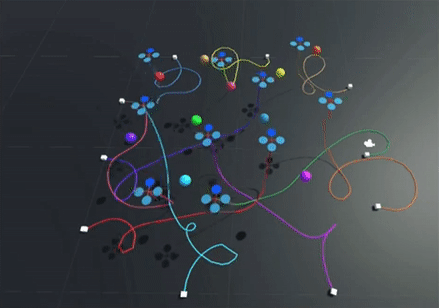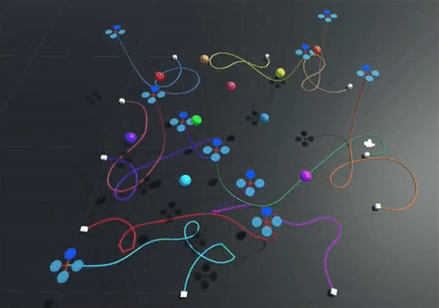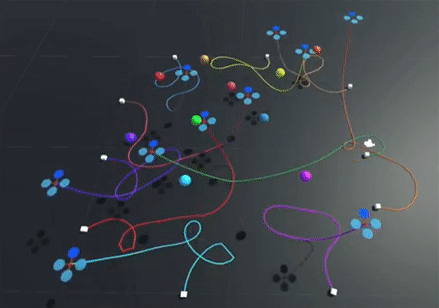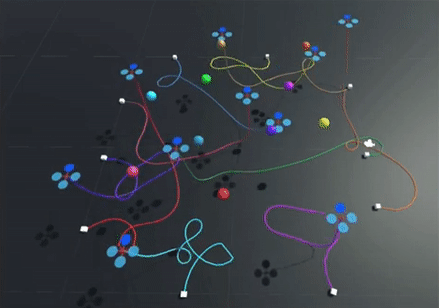
Braid-based entanglement-free trajectory planning for multiple tethered robots
The International Journal of Robotics Research (IJRR), 2025 — Honorable mention, IJRR Paper of the Season
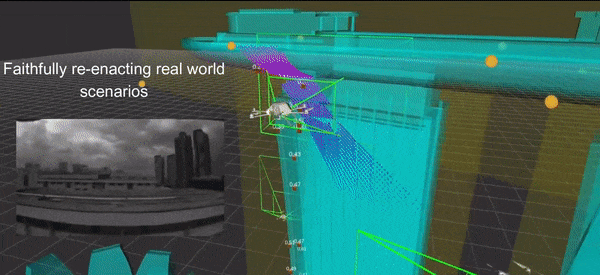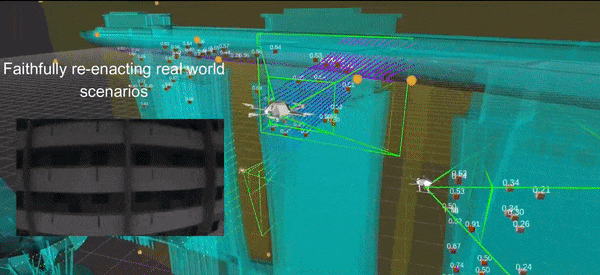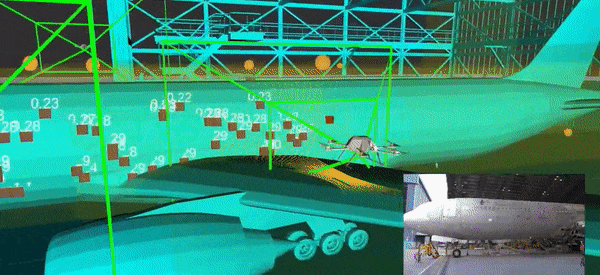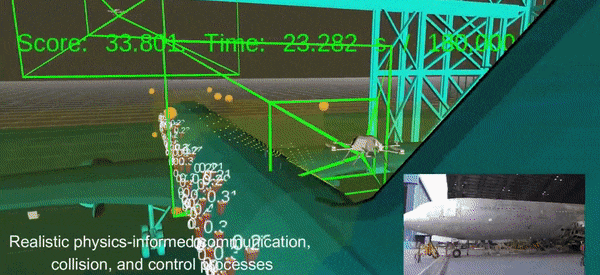
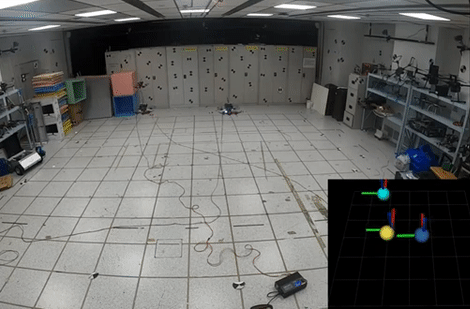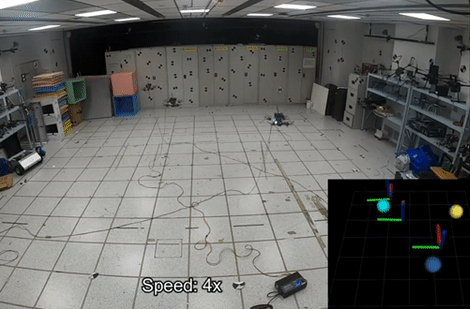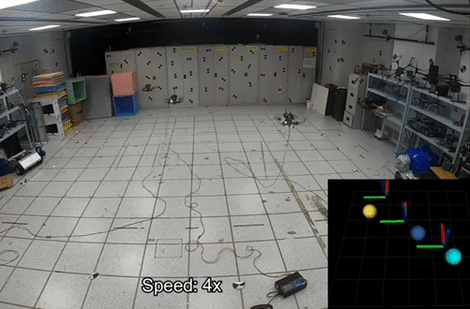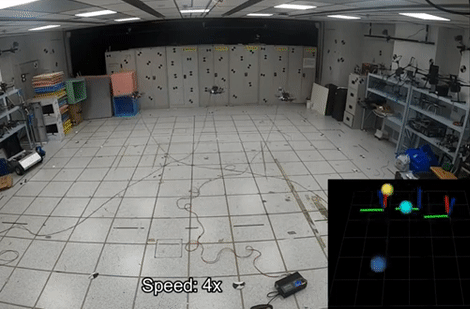
Path Planning for Multiple Tethered Robots Using Topological Braids
Robotics: Science and Systems (RSS), 2023